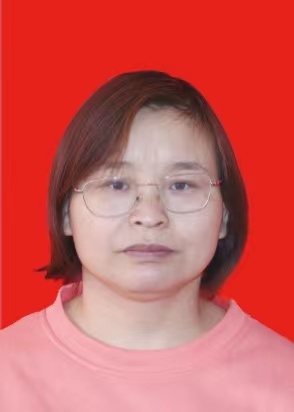
教师姓名:屈淑维
教师资料:工学博士,副教授,博士生导师
研究方向:机构及机器人创新设计,移动机器人,康复机器人
个人简介:2003年毕业于西北工业大学,2025年英国North England Robotics Innovation Center (NERIC)访问学者。主持并参与国家自然科学基金项目,山西省重点研发计划项目,中央引导地方发展资金项目,山西省国际交流合作项目,山西省自然科学基金项目,国家重点实验项目等十余项;获山西省自然科学二等奖1项,出版学术专著1部;发表学术论文30余篇,期中SCI收录13篇,EI收录5篇。授权国家发明专利4项;机械工程学会高级会员,山西省工业技术学会高级会员,国际学术期刊Transactions of the Canadian Society for Mechanical Engineering,Journal of the Brazilian Society of Mechanical Sciences and Engineering及Journal of Mechanical Science and Technology审稿人;中北大学师德师风先进个人;中北大学优秀主讲教师;创新实践平台优秀指导教师。
E-mail: shuweiqu1222@nuc.edu.cn
学术论文
[1] QU S., WANG H., FENG S., et al. Configuration design and kinematic analysis of RUPU/2UPU reconfigurable parallel Mechanism[J]. Mathematics, 2026, 14(07):1205. SCI: 001738801300001
[2] HAN Y., HAO B., QU S*., et al. Rapid solidification behavior and microstructural evolution of copper-based alloys under deep undercooling condition[J]. Journal of Wuhan University of Technology (Materials Science), 2026, 41(02): 512-522. SCI: 001738049400007
[3] QU S., LI Z., WANG H., et al. Microstructural evolution of rapidly solidified Ni-Cu alloys[J]. Journal of Wuhan University of Technology (Materials Science),2025,40(06):1759-1765. SCI 001627565300006
[4] QU S., LI C., WANG H., et al. Dynamic reconstruction of degrees of freedom and coupling control in 3RPUR metamorphic parallel mechanism[J]. Machines, 2025, 13(10): 894.,SCI:001601952400001
[5] QU S., FENG S., Li R., et al. Kinematics analysis of 3(rU)PU metamorphic parallel mechanism based on the full Jacobian matrix[J]. Journal of Mechanical Science and Technology, 2025, 40(10): 2657-2666. SCI 收录
[6] QU S. LI R., YAO W., et al. Structure design, kinematics analysis, and effect evaluation of a novel ankle rehabilitation robot[J]. Applied Science, 2023, 13(10), 6109. SCI收录
[7] QU S., LI R., MA C., et al. Type synthesis for lower-mobility decoupled parallel mechanism with redundant constraints[J]. Journal of Mechanical Science and Technology, 2021, 35(6): 2657-2666. SCI收录
[8] QU S.,LI R., BAI S., et al. A unified model for output accuracy of the open chain manipulators that considering joint clearance and structure parameters[J]. Journal of Mechanical Science and Technology, 2018, 33(10): 4925-4931. SCI收录
[9] QU S., LI R., BAI S. Type synthesis of 2T1R decoupled parallel mechanisms based on Lie groups and screw theory[J]. Mathematical Problems in Engineering, 2017, (1): 1~11. SCI收录
[10] QU S., LI R. Workspace analysis and application of the PRRRP decoupled parallel mechanism. Mechanism and Machine Science, 2016, 408: 973-985. EI 收录
[11] QU S., GUO Z., WANG F. The algorithm based on the discrete Fourier transform of eye detecting and locating. Modeling and Simulation, 2013: 521-525. EI 收录
[12] ZHANG H., DUAN S., HAN Q., HE Q., SHI Z., LIU L., S. Qu. Strength and proportioning design of 3D printed concrete (3DPC) based on aggregate gradation optimization[J]. Journal Information,2024,76 (5):2414-2425. SCI收录
[13] GUO Z., HOU H., ZHAO Y., QU S. Optimization of AZ80 magnes; alloy squeeze cast process parameters using morphological matrix[J]. Transactions of Nonferrous Metals Society of China, 2012, 22 (08):411-418. SCI收录
[14]冯盛权,屈淑维*,李瑞琴,等.基于变轴线运动副3(rU)PU变胞并联机构设计[J].中国机械工程 2026, 37(2): 361-373. EI:20261420432751
科研项目
[1] 山西省基础研究计划项目,人机共融下肢外骨骼康复机器人自适应设计及控制方法研究,主持。
[2] 中央引导地方发展资金项目,智能巡检-维护-救援可重构变胞移动机器人设计及应用,主持。
[3] 山西省基础研究计划项目,混联解耦下肢外骨骼康复机构综合与运动 /力传递性能及尺度优化,主持。
[4] 浙江大学CAD&CG全国重点实验室开放课题,仿生欠驱动抓持操作装备设计原理与构造技术,主持。
[5] 先进制造技术山西省重点实验室开放基金项目,混联机构解耦设计方法与应用研究,主持。
[6] 山西省研究生教育创新项目,并联机构解耦设计理论与应用研究,主持。
[7] 国家自然科学基金面上项目,多自由度混合驱动可控机构的设计理论与应用研究,参研。
[8] 国家自然科学基金面上项目, 镁合金电磁挤压铸造制备与应用研究,参研。
[9] 西省重点研发计划项目,适用于危险复杂环境的可重构移动机器人越障能力及其应用,参研。
[10]企业横向,电阻行业全自动无人立体库房设计;主持。
其他成果
[1]屈淑维著. 机构解耦理论模型与方法[M].北京:化学工业出版社,2022.6.
[2]并联机构型综合理论与方法及应用研究,山西省自然科学二等奖,排名4。
[3]屈淑维,郭志宏,温海骏,等.一种助稳式下肢外骨骼康复装备[P].NO: 2023201225488, 发明专利已受理。
[4]屈淑维,郭志宏,梁世杰,等.一种可实现两转三移的混联解耦机床[P],NO:2018070401662060,发明专利已授权。